Search

Hongke's latest articles

HongKe

Lorem ipsum dolor sit amet, consectetur adipiscing elit. Ut elit tellus, luctus nec ullamcorper mattis, pulvinar dapibus leo.

Lorem ipsum dolor sit amet, consectetur adipiscing elit. Ut elit tellus, luctus nec ullamcorper mattis, pulvinar dapibus leo.

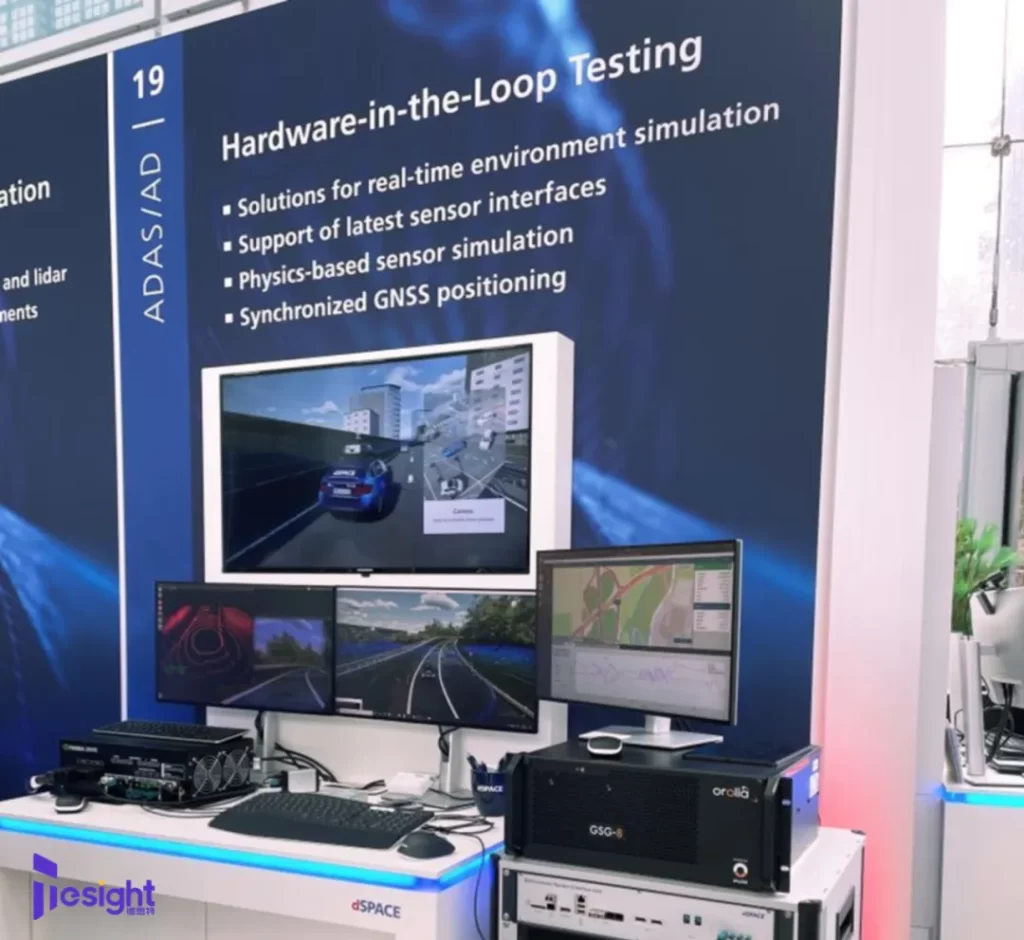
HONGKE Solutions] Enabling dSPACE to Realize GNSS-based HIL Simulation for Driving Functions, Accelerating the Revolution of Autonomous Driving Tests

dSPACE, a world-renowned provider of simulation and verification solutions, has successfully constructed a GNSS-based Hardware-in-the-Loop (HIL) simulation system for driving functions. The system can be widely used in automotive scenarios such as autonomous driving, V2X, and smart cabins, and is highly flexible and versatile, making it suitable for all kinds of complex test environments.

About dSPACE

dSPACE is a global player in the field of simulation and verification, and a pioneer in aerospace and defense innovation. Its product portfolio covers the entire development chain from conceptual design to mass production support for applications in autonomous driving, electric vehicles, motors, battery management systems, fuel cells, power electronics, charging infrastructure, and more.

dSPACE also offers a wide range of simulation models to support all stages of development, from functional development to ECU testing.

Program Introduction

The importance of GNSS signals in autonomous driving lies in their ability to provide accurate, reliable and stable positioning information. Whether it is V2X communication or autonomous driving function verification, all core applications rely on satellite-supported positioning capabilities.

However, the availability of different GNSS systems varies greatly, and the quality of GNSS signals can be easily affected by topographical environments (e.g., urban canyons, viaducts, dense buildings). In addition, GNSS signals can be subject to unintentional interference, malicious interference, or spoofing attacks.

To ensure the robustness and reliability of the application in everyday scenarios, it is essential to rely on more powerful and stable GNSS simulators.

Program Components

The whole system is mainly composed of the following parts:

  • HIL SimulatorIncludes Automotive Simulation Models (ASM) for simulating vehicle motion and traffic behavior.
  • GNSS blockset: Dedicated interface module set for controlling GNSS signal generators
  • GNSS Simulator GSG-8 GEN2Generate GNSS scenes with specific requirements based on the current geographic location and output vehicle position data in the form of RF signals.
  • Automotive Simulation Model (ASM)Simulates engines, vehicle dynamics, electrical components, and traffic environments, and supports model development and ECU-based HIL testing.

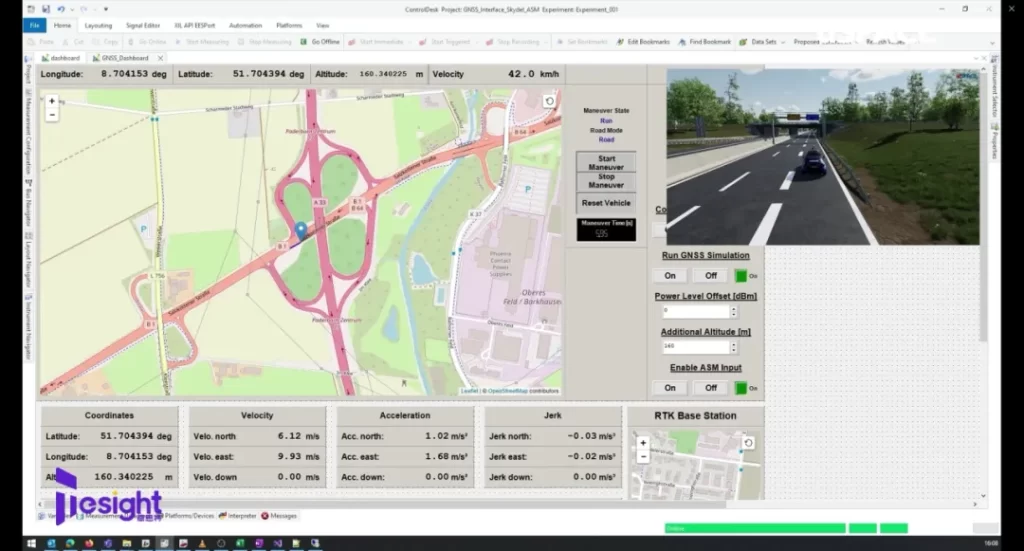
In this solution, the HIL simulator can specify the 3D trajectory and related scenes, and output the position information (latitude, longitude, altitude), 3-axis velocity, 3-axis acceleration and acceleration. Attitude information such as 3-axis angular velocity can be obtained using an ASM module, and the data is transmitted in real time to the GNSS simulator, which then feeds it back to the device to be tested using RF signals.

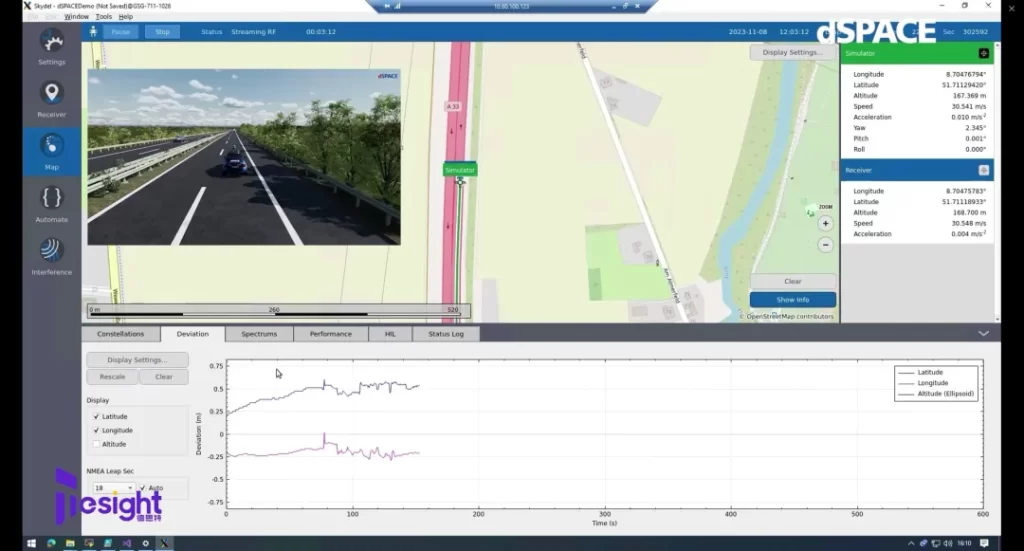
During the GNSS simulation process, you can observe the GNSS data output from the simulator and received from the device under test in real time, and you can check the positioning error and compare the performance of the simulation coordinates. By monitoring the interaction between the GNSS simulator and the DUT (Device Under Test) in real time, the performance of the positioning algorithm and GNSS modules in different environments can be more accurately evaluated.

In this way, the GNSS module can be fully integrated into HIL's 3D simulation scenarios, enabling it to perform a wide range of complex environmental and operational tests in a laboratory environment. The ability to simulate a wide range of road conditions and environmental changes without the need for extensive on-road measurements dramatically improves testing efficiency, while providing more quantifiable data for performance optimization and algorithm adjustment.

efficacy

The GNSS simulator enables highly accurate geolocation simulation and satellite signal generation. When the GNSS signal generator is integrated into the dSPACE ASM model, the system automatically selects the default GNSS test scene and controls the signal generator.

In a typical autonomous driving test, the starting position, date, driving route and driving maneuvers can be parameterized in the ASM model, and various GNSS constellations (GPS, Galileo, GLONASS, BeiDou, etc.) and signal degradation modes can be selected. the HIL simulator continuously transmits the vehicle position data to the signal generator, which generates a simulated signal based on the scene and outputs it as a real RF signal to the GNSS device to be tested. The HIL simulator continuously transmits the vehicle position data to the signal generator, which generates a simulated signal based on the scene and outputs it to the GNSS device to be tested in the form of a real RF signal.

Through this complete process, the positioning status, error behavior and performance limits of GNSS modules in various complex scenarios can be completely reconstructed, effectively supporting the rapid verification of autonomous driving perception and positioning tests.

Other Articles

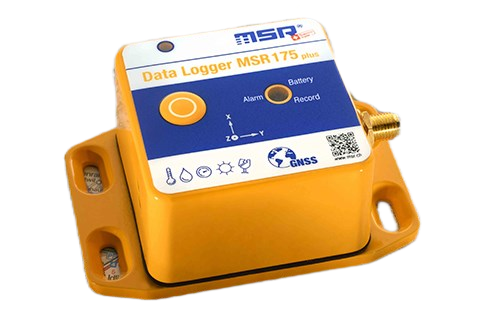
虹科 MSR175plus 衝擊與環境數據記錄器外觀圖:黃色堅固外殼配有 GNSS 定位功能、三軸加速度(X/Y/Z)以及溫度、濕度、氣壓、光照與傾斜感測器圖示,專用於運輸與物流監測。
Hongke Dry Goods

[Hongke Case Study] TSMC Selects MSR Shock and Vibration Data Loggers

How Can You Prevent Vibration Damage During International Transport of Semiconductor Wafers and Photomasks? We Reveal the Key Reasons TSMC Chose Hongke’s MSR175Plus Shock and Vibration Data Logger! The product features long battery life and large-capacity memory, enabling precise recording of temperature, humidity, pressure, and multi-axis acceleration during long-distance transport. In an exclusive interview, a TSMC engineer shares how the company converts vibration into quantifiable data and establishes rigorous standards to effectively reduce the risk of damage and significantly improve the success rate of international shipments!
Read more
PCB 電路板組裝視覺檢測與測量示意圖:陣列排列的印刷電路板(PCBA)在藍光光源下展示晶片、元件與金屬焊盤細節,適用於 SMT 表面貼裝自動光學檢測(AOI)與品質管控。
Hongke Dry Goods

[Hongke Solutions] How Can AI-Powered Industrial Vision Inspection Overcome Quality Bottlenecks? A Comprehensive Analysis of Multi-Camera PTP Synchronization and Defect Detection

An In-Depth Analysis of AI Industrial Vision Inspection Technology! Explore how high-resolution industrial cameras, AI deep learning algorithms, and IEEE 1588 PTP microsecond-level multi-camera time synchronization precisely overcome bottlenecks in PCB component measurement and lithium-ion battery defect detection, and SMT Automated Optical Inspection (AOI), thereby improving production line yield!

Read more
可配置的CAN FD模擬I/O模塊 功能概述: PCAN-MicroMod FD系列模塊是支持CAN FD的數采模塊。 PCAN-MicroMod FD 插入式板卡可以和即插即用的母板一起購買,母板提供了各種外設可滿足特定需要。對於CAN連接、I/O、和供電,可用彈簧端子連接器。 PCAN-MicroMod FD 數字版1和2著重於數字輸入和輸出,其上有相應的保護電路。數字1的數字輸出裝備了低邊開關,數字2的裝備了高邊開關。
Hongke Dry Goods

[Hongke Solutions] Can’t Read CAN Data? Not Enough Temperature Channels? A Comprehensive Guide to Integrating NVH and Battery Data Acquisition

Is your current NVH data logger unable to read the CAN bus? Are there not enough temperature channels for battery testing? Hongke offers the PCAN-MicroMod FD and MU-Thermocouple1 CAN FD modules to enable CAN(FD)-to-analog conversion and high-density thermocouple multi-module cascading expansion. No coding required—just unbox and use it right away, with no need to replace your existing system!

Read more

Contact Hongke to help you solve your problems.

Let's have a chat