Search

Hongke's latest articles

HongKe

Lorem ipsum dolor sit amet, consectetur adipiscing elit. Ut elit tellus, luctus nec ullamcorper mattis, pulvinar dapibus leo.

Lorem ipsum dolor sit amet, consectetur adipiscing elit. Ut elit tellus, luctus nec ullamcorper mattis, pulvinar dapibus leo.

HONGKE Solutions] Enabling dSPACE to Realize GNSS-based HIL Simulation for Driving Functions, Accelerating the Revolution of Autonomous Driving Tests

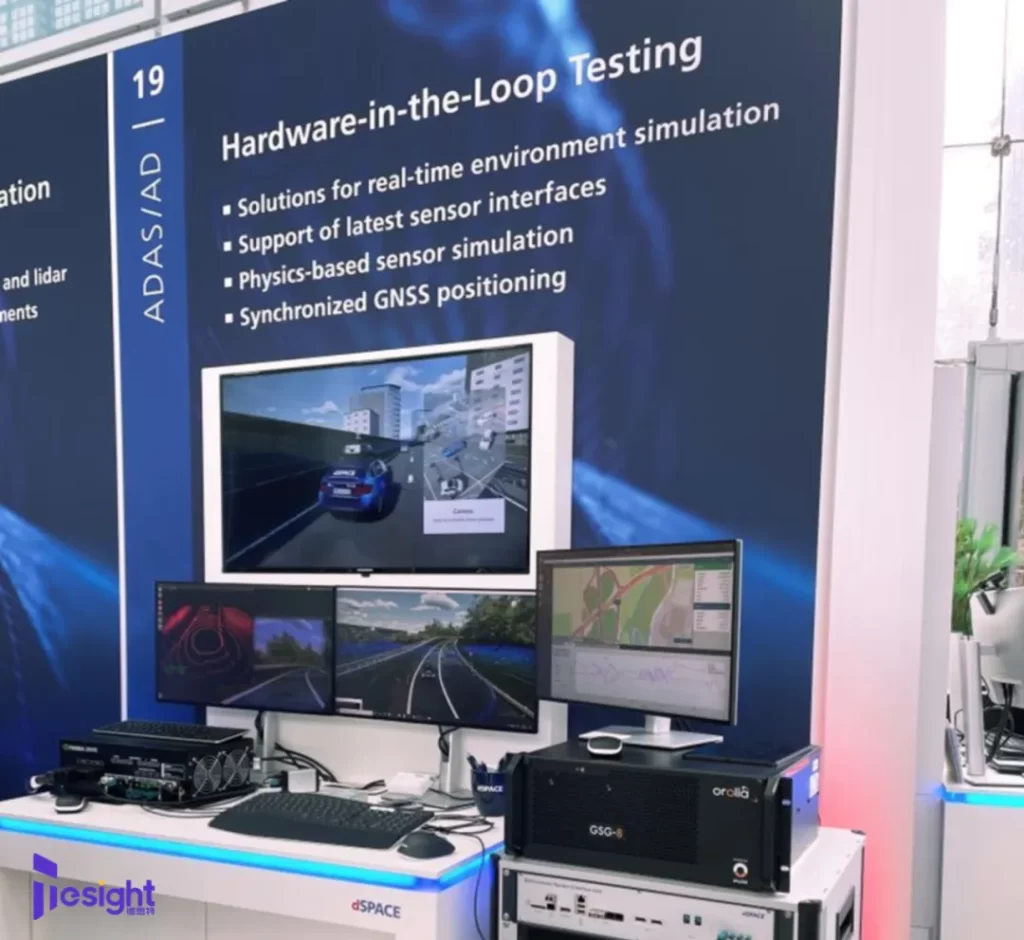
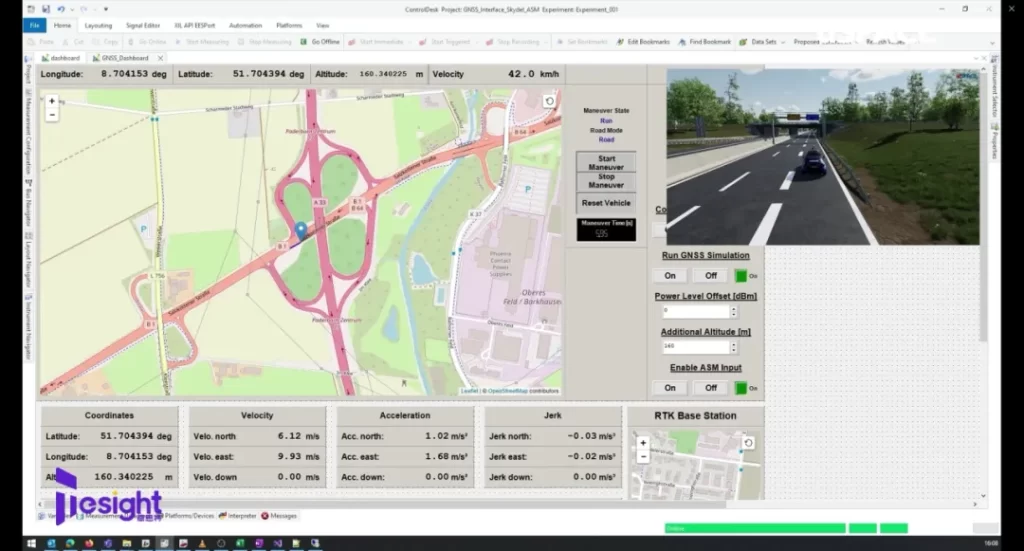
dSPACE, a world-renowned provider of simulation and verification solutions, has successfully constructed a GNSS-based Hardware-in-the-Loop (HIL) simulation system for driving functions. The system can be widely used in automotive scenarios such as autonomous driving, V2X, and smart cabins, and is highly flexible and versatile, making it suitable for all kinds of complex test environments.

About dSPACE

dSPACE is a global player in the field of simulation and verification, and a pioneer in aerospace and defense innovation. Its product portfolio covers the entire development chain from conceptual design to mass production support for applications in autonomous driving, electric vehicles, motors, battery management systems, fuel cells, power electronics, charging infrastructure, and more.

dSPACE also offers a wide range of simulation models to support all stages of development, from functional development to ECU testing.

Program Introduction

The importance of GNSS signals in autonomous driving lies in their ability to provide accurate, reliable and stable positioning information. Whether it is V2X communication or autonomous driving function verification, all core applications rely on satellite-supported positioning capabilities.

However, the availability of different GNSS systems varies greatly, and the quality of GNSS signals can be easily affected by topographical environments (e.g., urban canyons, viaducts, dense buildings). In addition, GNSS signals can be subject to unintentional interference, malicious interference, or spoofing attacks.

To ensure the robustness and reliability of the application in everyday scenarios, it is essential to rely on more powerful and stable GNSS simulators.

Program Components

The whole system is mainly composed of the following parts:

  • HIL SimulatorIncludes Automotive Simulation Models (ASM) for simulating vehicle motion and traffic behavior.
  • GNSS blockset: Dedicated interface module set for controlling GNSS signal generators
  • GNSS Simulator GSG-8 GEN2Generate GNSS scenes with specific requirements based on the current geographic location and output vehicle position data in the form of RF signals.
  • Automotive Simulation Model (ASM)Simulates engines, vehicle dynamics, electrical components, and traffic environments, and supports model development and ECU-based HIL testing.

In this solution, the HIL simulator can specify the 3D trajectory and related scenes, and output the position information (latitude, longitude, altitude), 3-axis velocity, 3-axis acceleration and acceleration. Attitude information such as 3-axis angular velocity can be obtained using an ASM module, and the data is transmitted in real time to the GNSS simulator, which then feeds it back to the device to be tested using RF signals.

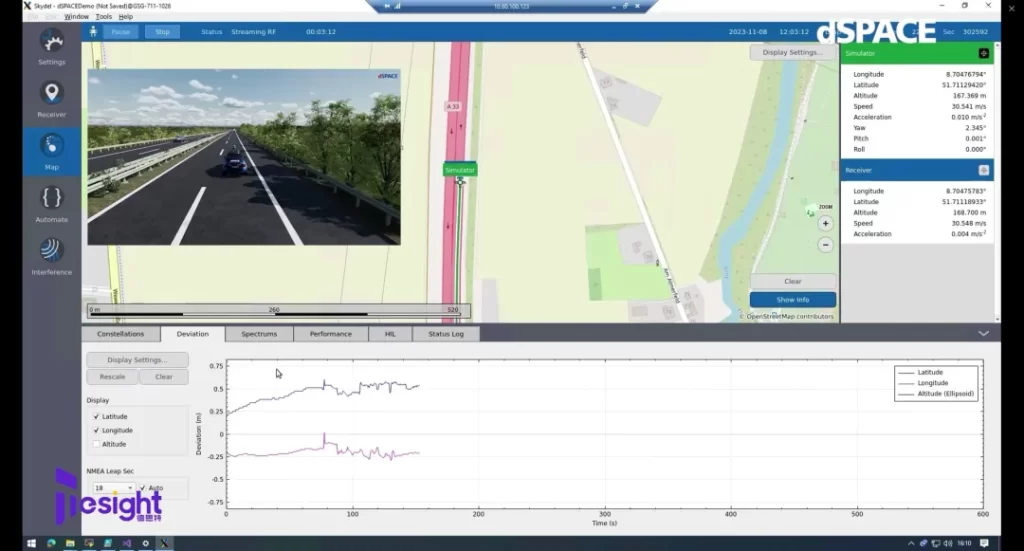
During the GNSS simulation process, you can observe the GNSS data output from the simulator and received from the device under test in real time, and you can check the positioning error and compare the performance of the simulation coordinates. By monitoring the interaction between the GNSS simulator and the DUT (Device Under Test) in real time, the performance of the positioning algorithm and GNSS modules in different environments can be more accurately evaluated.

In this way, the GNSS module can be fully integrated into HIL's 3D simulation scenarios, enabling it to perform a wide range of complex environmental and operational tests in a laboratory environment. The ability to simulate a wide range of road conditions and environmental changes without the need for extensive on-road measurements dramatically improves testing efficiency, while providing more quantifiable data for performance optimization and algorithm adjustment.

efficacy

The GNSS simulator enables highly accurate geolocation simulation and satellite signal generation. When the GNSS signal generator is integrated into the dSPACE ASM model, the system automatically selects the default GNSS test scene and controls the signal generator.

In a typical autonomous driving test, the starting position, date, driving route and driving maneuvers can be parameterized in the ASM model, and various GNSS constellations (GPS, Galileo, GLONASS, BeiDou, etc.) and signal degradation modes can be selected. the HIL simulator continuously transmits the vehicle position data to the signal generator, which generates a simulated signal based on the scene and outputs it as a real RF signal to the GNSS device to be tested. The HIL simulator continuously transmits the vehicle position data to the signal generator, which generates a simulated signal based on the scene and outputs it to the GNSS device to be tested in the form of a real RF signal.

Through this complete process, the positioning status, error behavior and performance limits of GNSS modules in various complex scenarios can be completely reconstructed, effectively supporting the rapid verification of autonomous driving perception and positioning tests.

Other Articles

Hongke Dry Goods

[Hongke Solutions] Does AI Struggle to Understand Business Needs? Overcoming AI Context Disconnects and Real-Time Data Bottlenecks in Enterprises

Failed Enterprise AI Implementation? The Problem Isn’t the LLM Model! Hongke analyzes the devastating impact of the “Enterprise AI Context Gap” on Copilot and Agentic workflows and introduces the Redis Iris real-time context layer architecture to help B2B enterprises in Hong Kong and Southeast Asia build high-return AI systems.
Read more
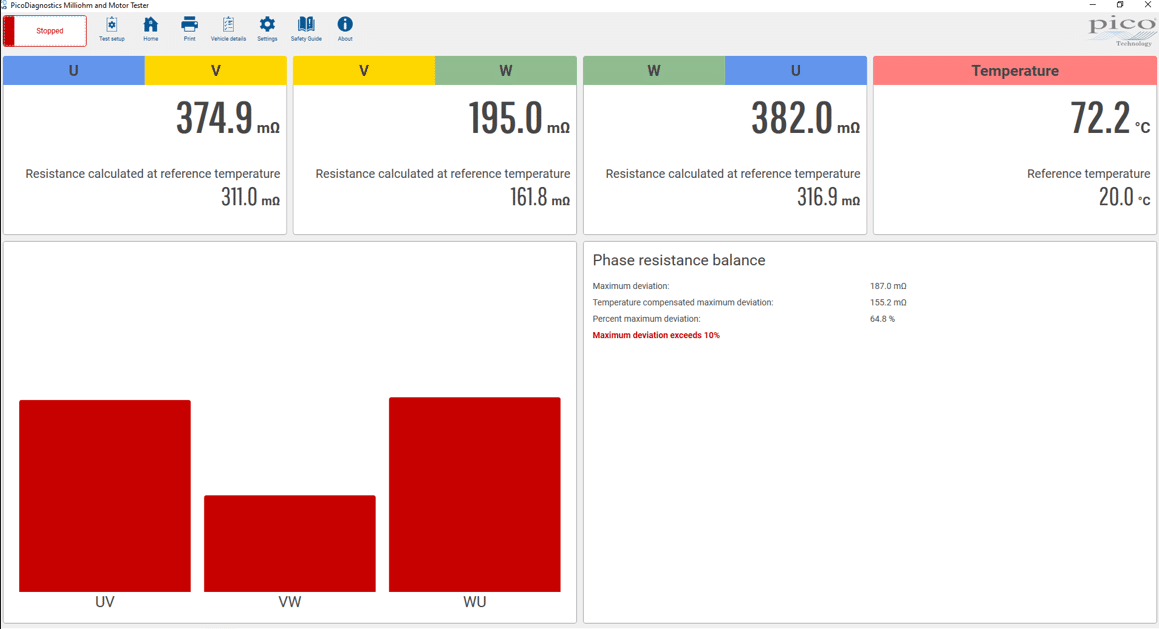
PicoDiagnostics 毫歐與馬達測試儀軟體介面:測量 BMW Valvetronic 三相馬達繞組阻值,顯示 U-V (374.9 mΩ)、V-W (195.0 mΩ) 與 W-U (382.0 mΩ) 存在 187.0 mΩ(64.8%)的嚴重不平衡,遠超 10% 容許上限。
Hongke Case

[Hongke Case Study] Using the Pico MT03A to Clear BMW Valvetronic Trouble Codes

BMW Reports DTCs 135808 and 135B11—Does That Mean You Have to Replace Parts Blindly? We Reveal How to Use the Pico MT03A Milliohm Meter and PicoScope Oscilloscope to Accurately Debunk Valvetronic Diagnostic Myths! Practical Testing Identifies 190 mΩ Motor Winding Imbalance and 5V Floating Ground, Avoiding False Open-Circuit Diagnoses and Significantly Improving Advanced Automotive Diagnostic Efficiency!

Read more
Hongke Dry Goods

[Hongke Solutions] ArangoDB Contextual Data Platform: Key Architecture for Next-Generation Network Asset Management (CAM/CMDB)

An in-depth analysis of how enterprises can transition from single LLM API calls to autonomous agentic systems. This article compiles real-world examples of AI agent deployments in production environments across six major industries, including retail and finance, and breaks down the underlying infrastructure logic—such as high concurrency, cross-interaction memory (Memory Infrastructure), and distributed state persistence.

Read more

Contact Hongke to help you solve your problems.

Let's have a chat