Search

Hongke's latest articles

HongKe

Lorem ipsum dolor sit amet, consectetur adipiscing elit. Ut elit tellus, luctus nec ullamcorper mattis, pulvinar dapibus leo.

Lorem ipsum dolor sit amet, consectetur adipiscing elit. Ut elit tellus, luctus nec ullamcorper mattis, pulvinar dapibus leo.

HongKe Solutions] Redefining Precision Collaboration: How Low-Cost CAN FD Gives Robots "Fingertip Intelligence"?

High-efficiency control system based on CAN FD technology for the Hongke Nimble Hand

In the R&D landscape of humanoid robots, dexterous hands are the key bridge connecting technological conception and practical application. In order to realize millimeter-level motion and millinews-level force control, a set of efficient and accurate testing and verification program is the core guarantee for this pair of "robotic hands" to move from laboratory prototype to mass production.

The CAN FD technology-based test solution created by HONGKE is a deep integration of high-speed communication, intelligent monitoring and precise control, providing full-dimensional capability support for the R&D, quality inspection and application of the dexterous hand. The Smart Hand, which is the core execution task in this program, comes from HTC's partner, Smart Smart, and its excellent hardware performance provides a key carrier for the value verification of HTC's test program.

When Dexterity Meets CAN FD: Industry Pain Points and Technology Opportunities

As the core execution part of humanoid robot, robot dexterous hand needs to be equipped with multi-degree-of-freedom movement, force sensing and precise operation ability, and its application scenarios cover various fields such as industrial sorting, medical rehabilitation and scientific research experiments.

In order to realize the precise testing of "millimeter-level motion and milli-Nm-level force control" of dexterous hands, the traditional communication and testing means have the pain points of insufficient bandwidth, poor real-time performance, and complicated data parsing.

In the robotics industry, EtherCAT or CAN FD is often used as the core communication protocol. Among them, CAN FD stands out for its stable transmission quality and extremely low cabling costs.

As an upgraded version of the traditional CAN bus, CAN FD raises the data segment transmission rate to 8 Mbps and extends the data load to 64 bytes per frame, while retaining the advantages of high reliability and real-time performance of the CAN bus, which is a perfect match for the needs of dexterous robots for "high-speed command transmission + multi-sensor data return".

The core of HTC's solution: the three-in-one technology synergy

With the core logic of "communication + monitoring + control", HONGKE's dexterous motion control solution builds up a complete verification link from signal acquisition to motion execution, so that every action and every set of data of the dexterous hand can be monitored and adjusted.

Dexterity Unit

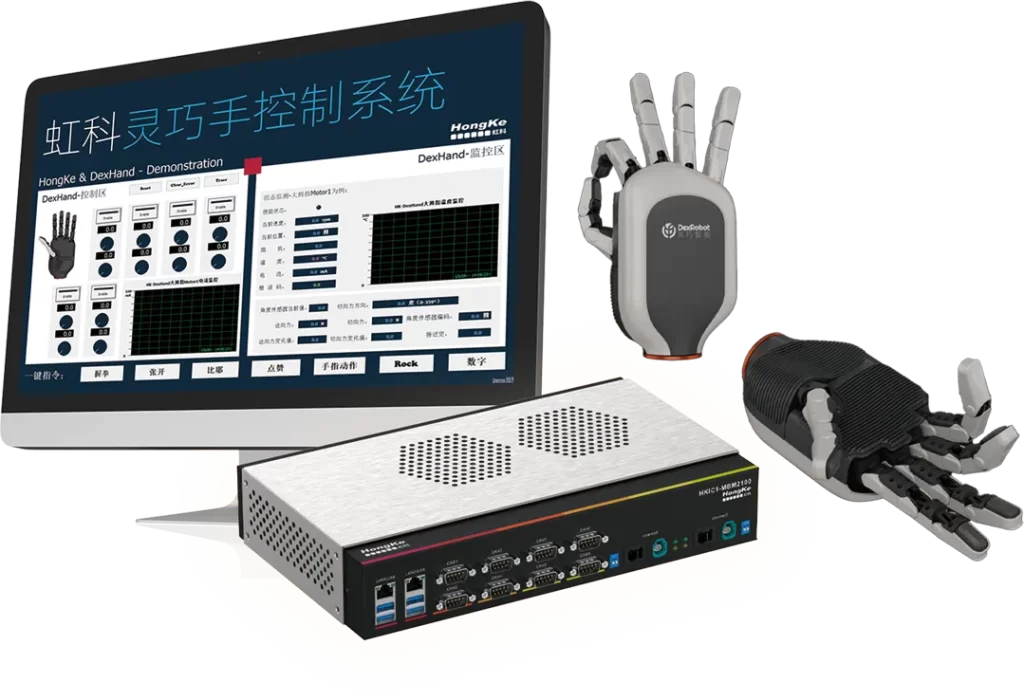
Supplied by Hongke's partner, Dexterous Intelligence, this dexterous hand features a high degree of freedom (e.g., 19DOF), high-precision force/position sensors, and a biomimetic structure design that reproduces anthropomorphic movements and fine manipulation, and is the core execution unit of the test solution.

CAN FD Test Tool

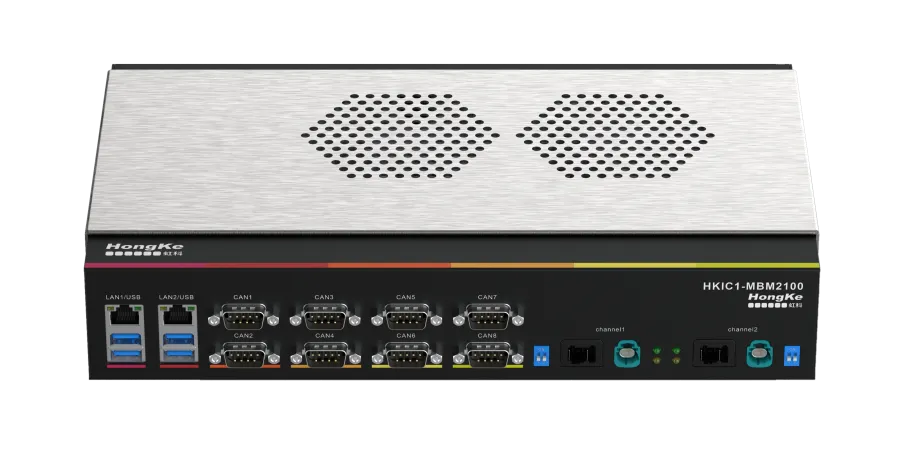
HONGKEI supports 8 CAN(FD) and 2 1000BASE-T1 bus workstations with 1 Mbps transmission rate for smart arbitration segment, 5 Mbps transmission rate for data segment, and 64-bit single frame load with 1-microsecond timestamping accuracy, which provides the hardware cornerstone for "high-speed command issuance + real-time data return".

HONGKE's Vehicle Network Communication Test Board is a high-performance industrial controller motherboard for monitoring, emulating, and simulating CAN(FD) and T1 network messages with powerful data processing and communication capabilities. It integrates 8 CAN(FD) interfaces and 2 1000BASE-T1 interfaces, and is compatible with PCAN underlay driver, which meets the test and data transmission requirements in complex communication network environments, and is widely used in automotive research and development, intelligent transportation, and vehicle inspection.

Customized Software Platform -- Hongke PCAN-Explorer 6

Based on HONGKE's PCAN-Explorer 6, the software platform is specially adapted to the communication protocols of the Dexterity Smart Hand, making the complex testing process simple and efficient:

Signal Monitoring

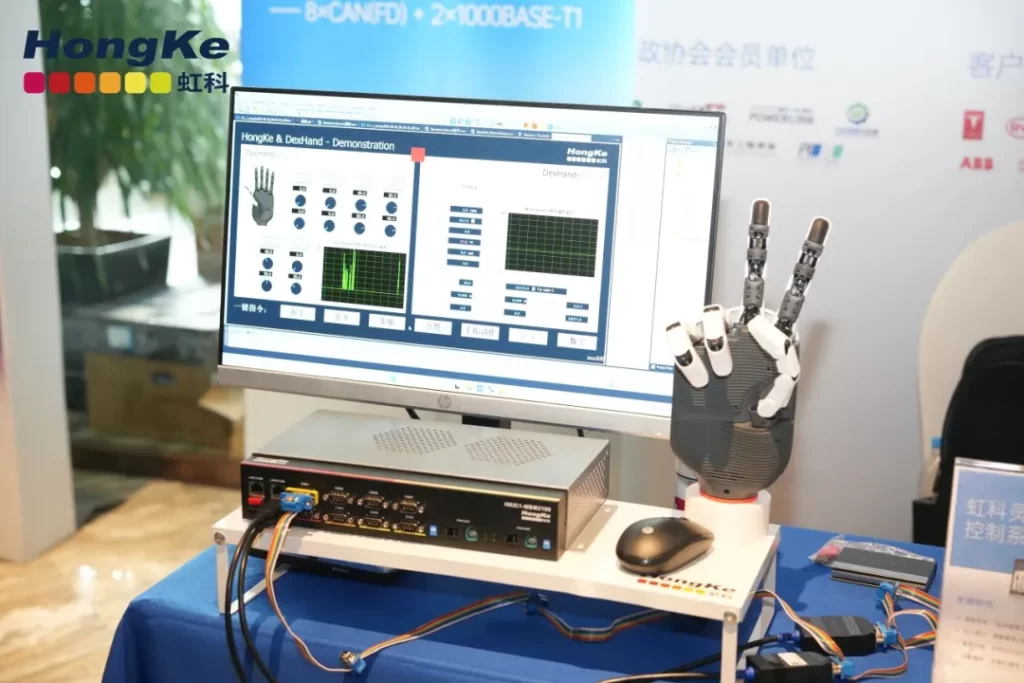
Instantly collects and analyzes the multi-dimensional signals from the motor current, temperature, angle sensor, force sensor, etc. of the dexterous hand, and presents them in the form of graphs and charts (as shown in this article's "Left and Right Hand Software Monitoring Chart", you can independently monitor the status of the motor and sensor data of the left hand and the right hand, respectively).

Instruction to send

It supports one-touch motion command sending for key gestures, and also realizes fine motion control for single-joint and multi-joint through the parameterized interface, with a measured delay deviation of less than 5 microseconds to meet the synchronization requirements of milli-Nm force control.

Data Analysis

Converts raw data on the CAN FD bus into easy-to-understand physical quantities through database file parsing and supports data logging, offline analysis and fault tracing.

System Deployment: From Communication Testing to Anthropomorphic Control

The whole system deployment process is simple and efficient, and no complicated professional operation is required to complete the test preparation.

Quickly establish communication links

As shown in the figure, the whole system consists of Dexterous Intelligent Smart Hands, HONGKE BUS workstations and the host computer (running HONGKE PCAN-Explorer 6 customization project).

After completing the hardware connection, the "Bus Configuration" module of Avision PCAN-Explorer 6 can be used to set the CAN FD communication parameters (e.g., baud rate, communication data, etc.) to establish a high-speed communication link between the dexterous hand and the test tool.

Establishment of database and multi-dimensional signal monitoring - "status transparency" for dexterous hands

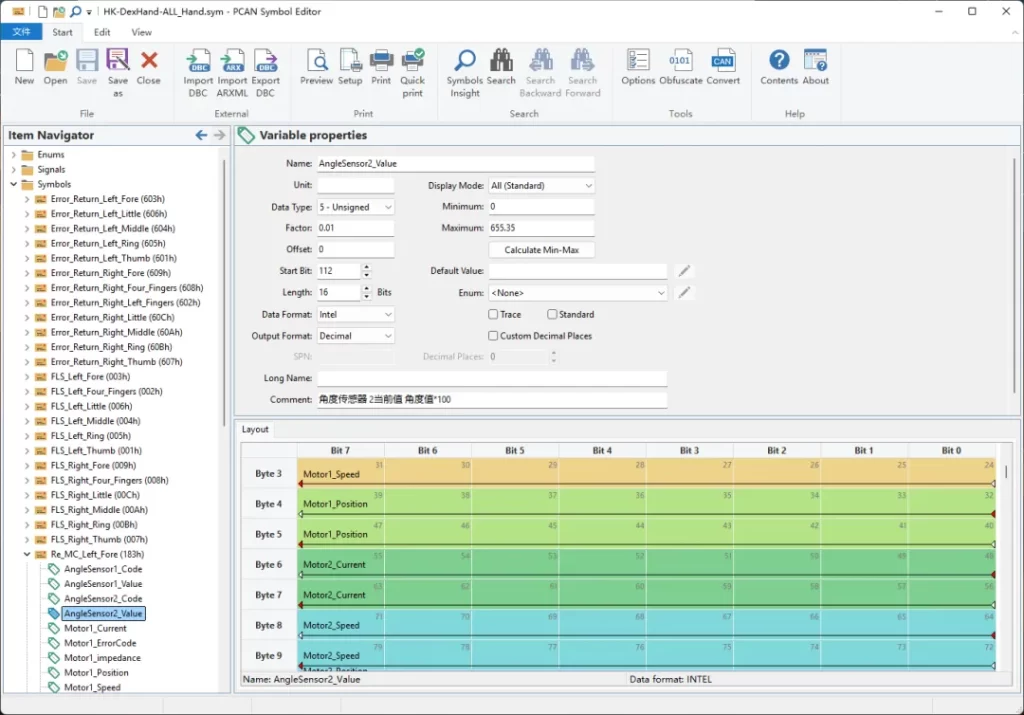
In the Symbol Editor of the PCAN-Explorer 6 software, you can freely create a CAN (FD) bus-based communication database, including descriptions of specific messages and signals, layout configurations, and various data parameters that may be used in virtual variables or customized projects.

By loading database files, customized projects can be advanced from the "link level" to the "application level", allowing even non-technical people to complete basic communication tests and command drivers with this set of customized projects:

  • Motor status monitoringReal-time monitoring of motor speed, position, current and temperature to ensure safe operation.

  • Sensor Data MonitoringAnalyze the output of angle sensors and force sensors (normal force, tangential force) to verify the positional accuracy and force control performance.

  • Communication status monitoringReal-time tracking of CAN FD bus load rate and error frames to ensure communication link stability.

From Lab to Application: Accelerating the Industrialization of Dexterous Hands

Based on the CAN FD technology, the HONGKEI robotics dexterity test solution constructs a complete, high-precision full-link test system through the deep synergy of hardware and software.

With the professional technical structure of "hardware accurate transmission + software intelligent analysis" and the strict logic of traceability of the whole chain data and reproducibility of the testing process, the solution not only provides quantitative support for the iteration of dexterous hand technology, but also becomes an important technological benchmark for the development of standardization and precision in the robotics industry.

At present, the dexterous hand has been applied in mass production in the fields of industrial sorting and power inspection, etc., and the solution will continue to provide reliable technical guarantee and testing support for its industrialization and large-scale landing.

Other Articles

可配置的CAN FD模擬I/O模塊 功能概述: PCAN-MicroMod FD系列模塊是支持CAN FD的數采模塊。 PCAN-MicroMod FD 插入式板卡可以和即插即用的母板一起購買,母板提供了各種外設可滿足特定需要。對於CAN連接、I/O、和供電,可用彈簧端子連接器。 PCAN-MicroMod FD 數字版1和2著重於數字輸入和輸出,其上有相應的保護電路。數字1的數字輸出裝備了低邊開關,數字2的裝備了高邊開關。
Hongke Dry Goods

[Hongke Solutions] Can’t Read CAN Data? Not Enough Temperature Channels? A Comprehensive Guide to Integrating NVH and Battery Data Acquisition

Is your current NVH data logger unable to read the CAN bus? Are there not enough temperature channels for battery testing? Hongke offers the PCAN-MicroMod FD and MU-Thermocouple1 CAN FD modules to enable CAN(FD)-to-analog conversion and high-density thermocouple multi-module cascading expansion. No coding required—just unbox and use it right away, with no need to replace your existing system!

Read more
Hongke Dry Goods

[Hongke Solutions] AI Agent Implementation Case Study: Enterprise-Level Deployment Across Six Major Industries and the Logic Behind the Underlying Infrastructure

An in-depth analysis of how enterprises can transition from single LLM API calls to autonomous agentic systems. This article compiles real-world examples of AI agent deployments in production environments across six major industries, including retail and finance, and breaks down the underlying infrastructure logic—such as high concurrency, cross-interaction memory (Memory Infrastructure), and distributed state persistence.

Read more
Hongke Dry Goods

HONGKE SOLUTIONS] The Effect of Gaussian Noise on Positioning Effect in GNSS Simulation

In Global Navigation Satellite System (GNSS) radio frequency simulation testing, Gaussian white noise (AWGN) is typically regarded as the baseline configuration for replicating real-world electromagnetic environments. However, engineering practice has shown that the impact of noise on a receiver’s positioning performance does not follow a linear, monotonic relationship. Based on actual measurement data from the DST GNSS simulator, this paper analyzes the physical mechanisms of Gaussian noise in Kalman filters, correlator jitter, and phase-locked loops, and provides a scientific testing guide for configuring simulation noise.

Read more

Contact Hongke to help you solve your problems.

Let's have a chat